Overview
As a member of the Stanford Space Initiative Rocketry and Liquid Propulsion teams, I work across both high-power solid rocketry and liquid propulsion development. I earned my NAR High Power Rocketry Level 1 certification by designing, building, and successfully flying an I-motor rocket with motor ejection and parachute recovery. Since then I have designed a single-stage Level 2 rocket and a two-stage hot-staging rocket.
Level 1 Certification Flight
The L1 project involved end-to-end design and fabrication. This photo shows my L1 rocket on the launch rail.
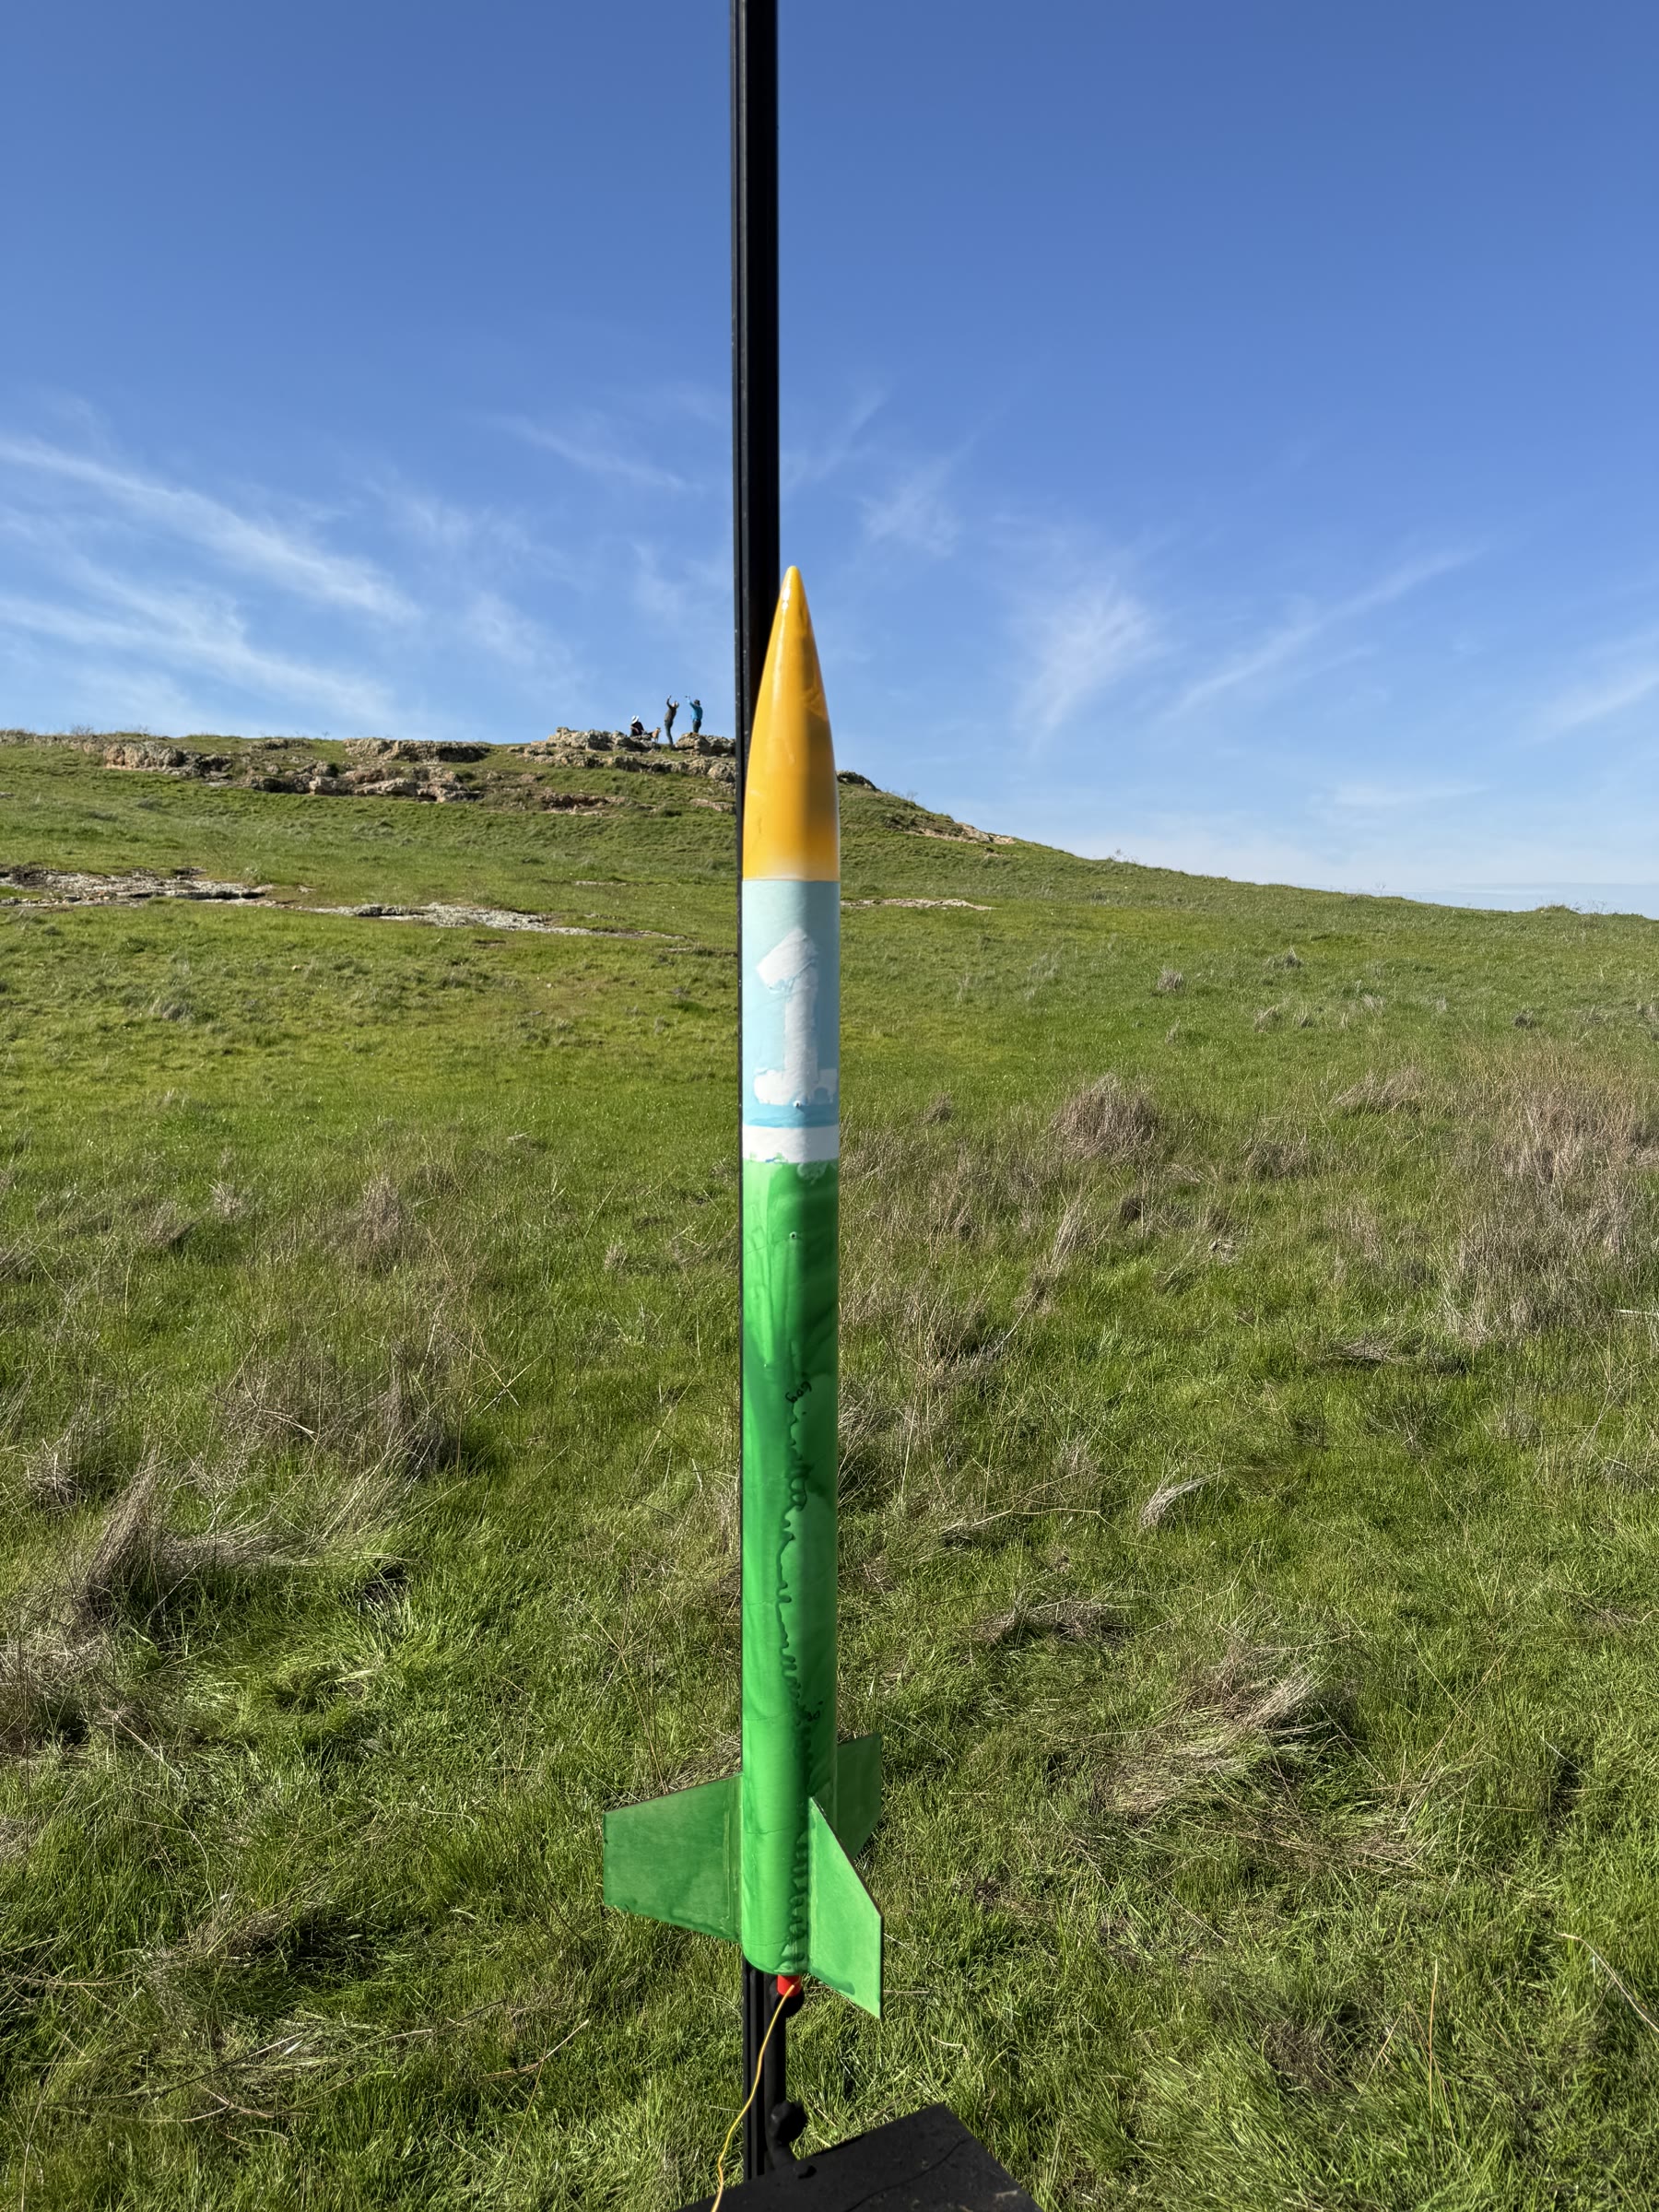
The work included:
- Airframe sizing and stability analysis (static margin, CP/CG sweep) for the I-motor impulse class
- Nose cone and fin geometry CAD, fin can layup
- Motor ejection charge sizing for reliable apogee deployment
- Successful flight and recovery, earning the L1 certification
Level 2 Rocket
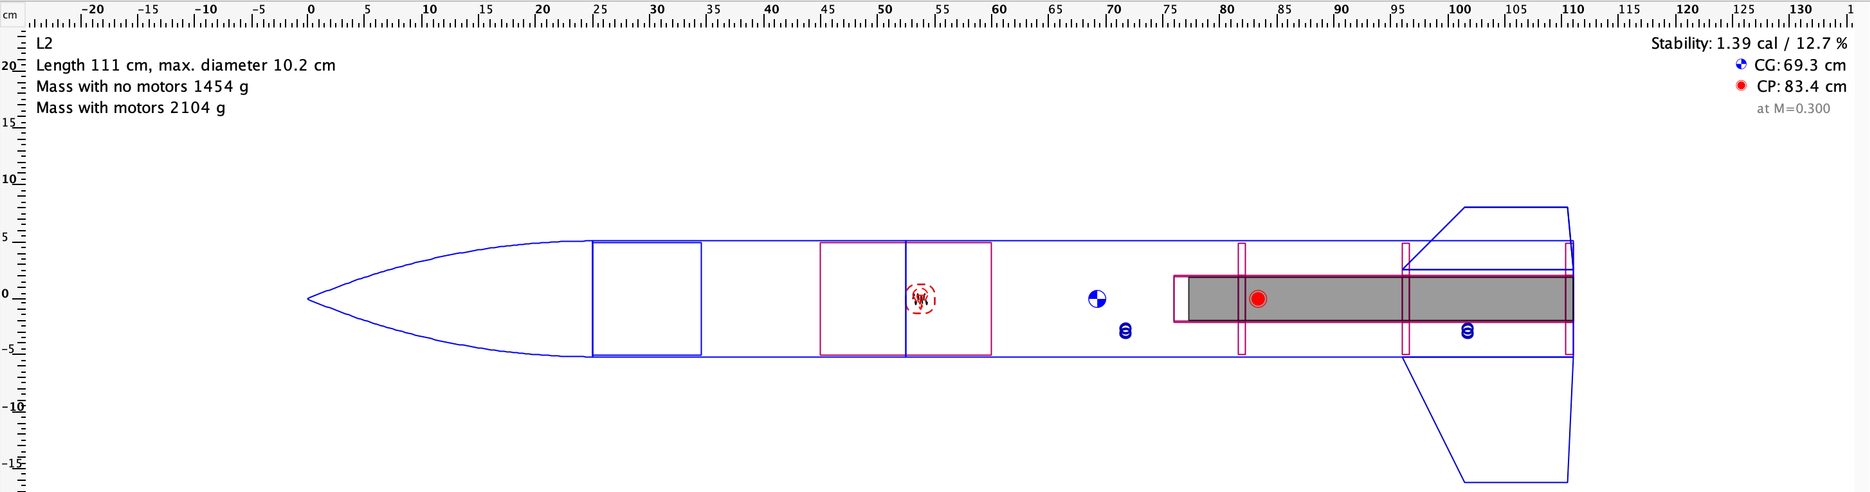
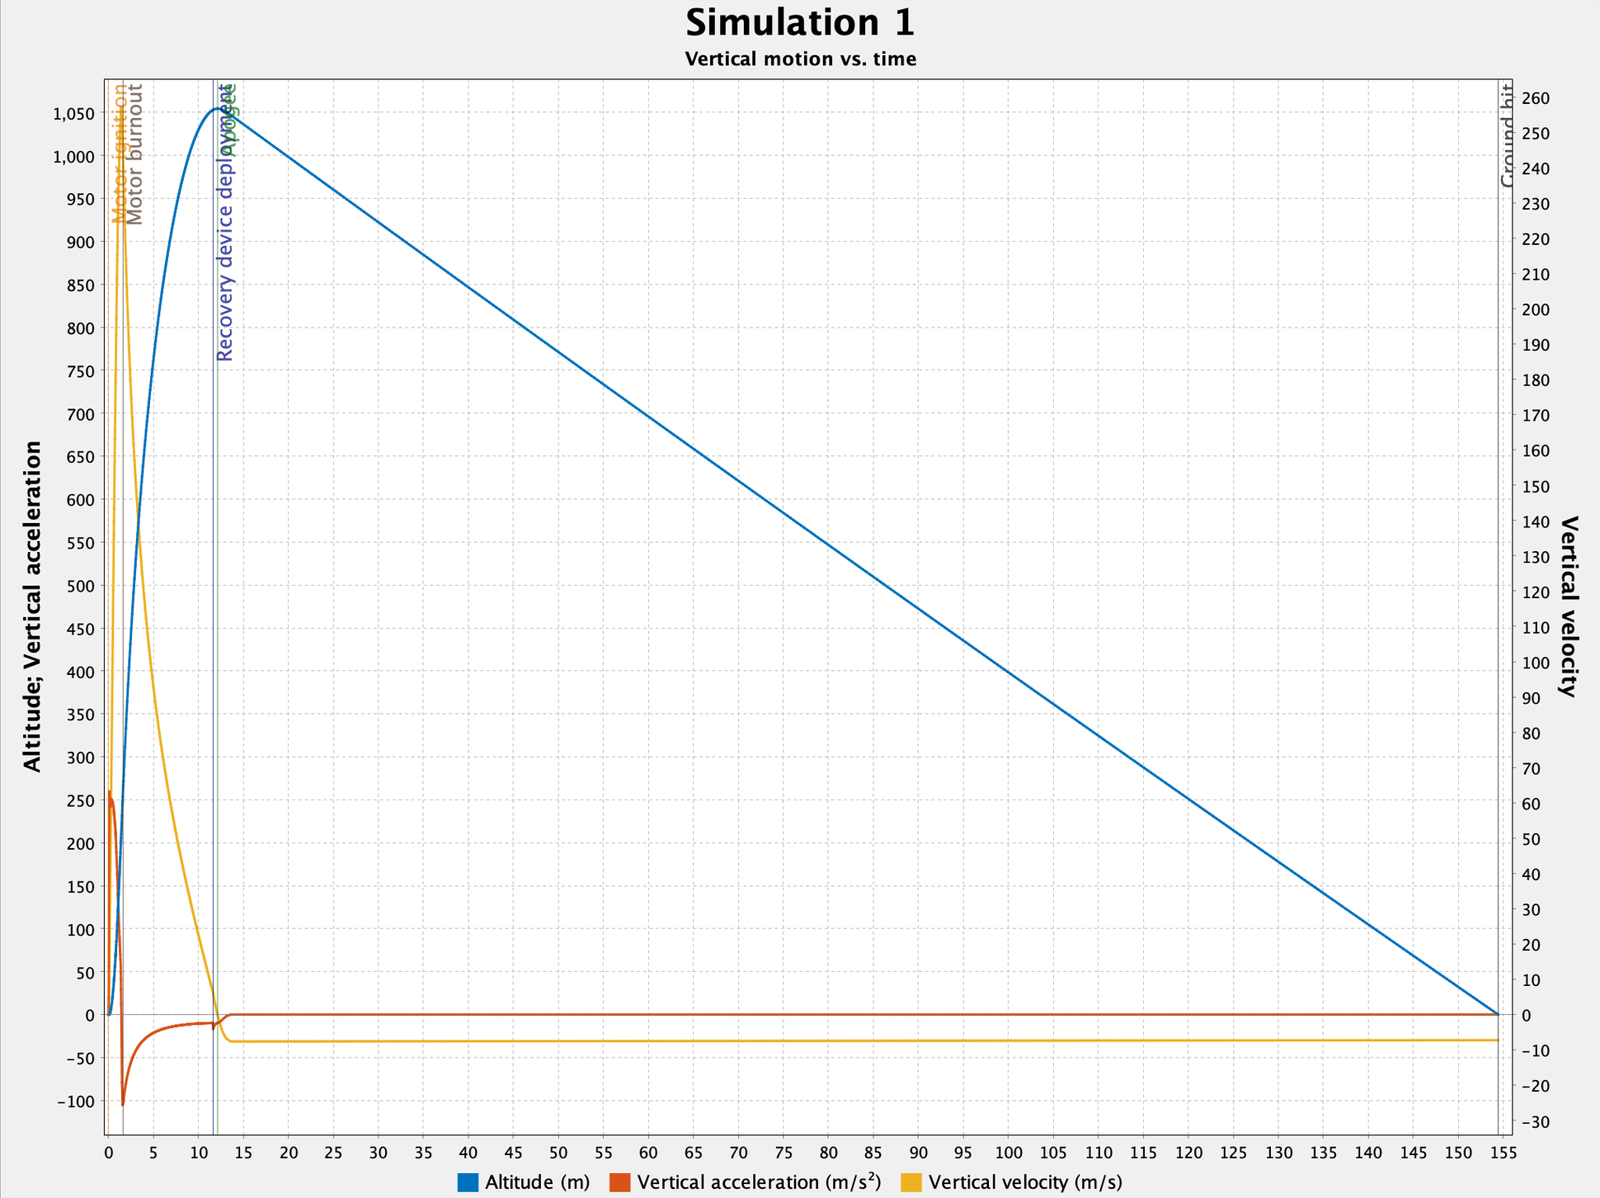
My Level 2 rocket is a single-stage airframe, 111 cm long with a 10.2 cm maximum diameter, designed around a J420R motor. In OpenRocket the rocket weighs 1454 g empty and 2104 g with the motor loaded. The simulation peaks at about 257 m/s (Mach 0.76) at burnout, then coasts to about 1,055 m.
Hot-Staging Rocket
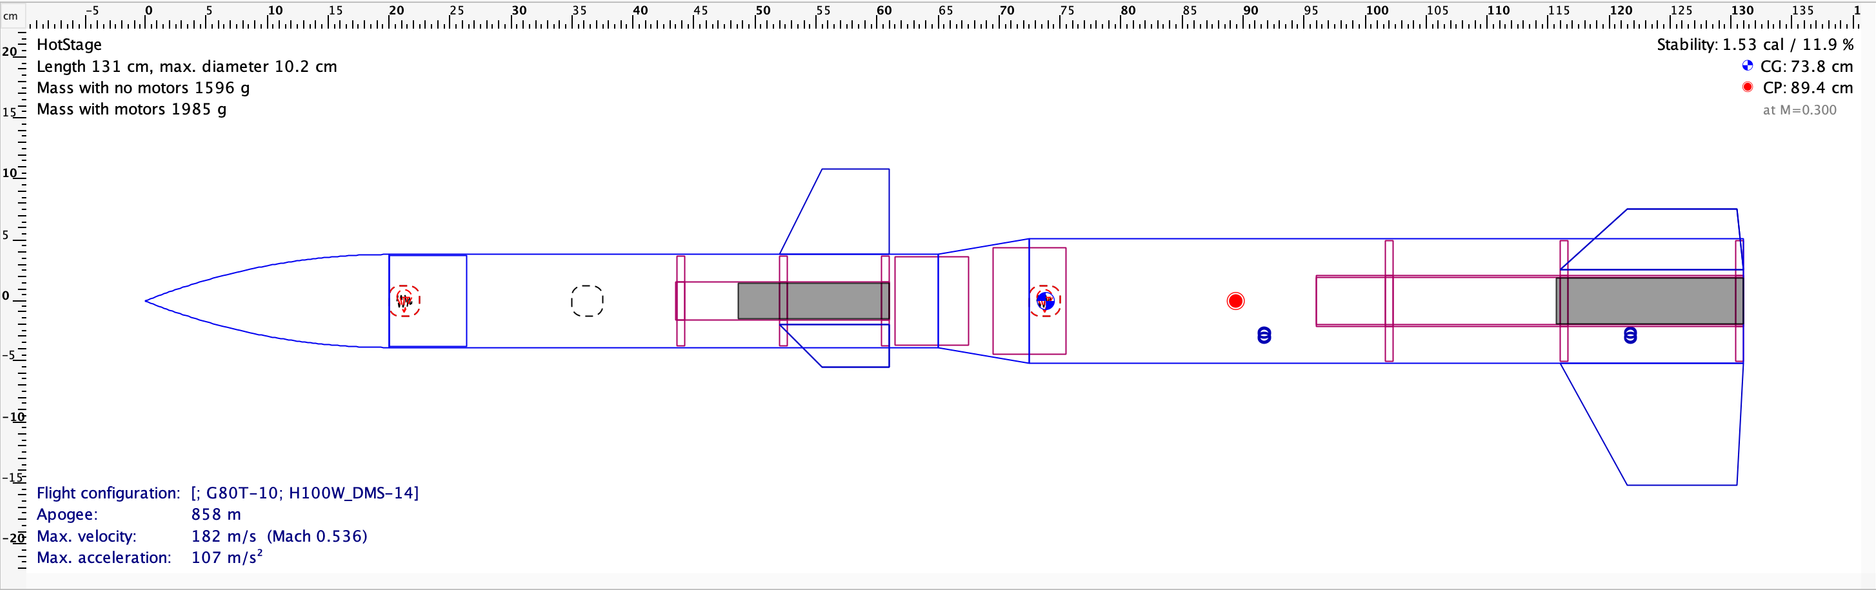
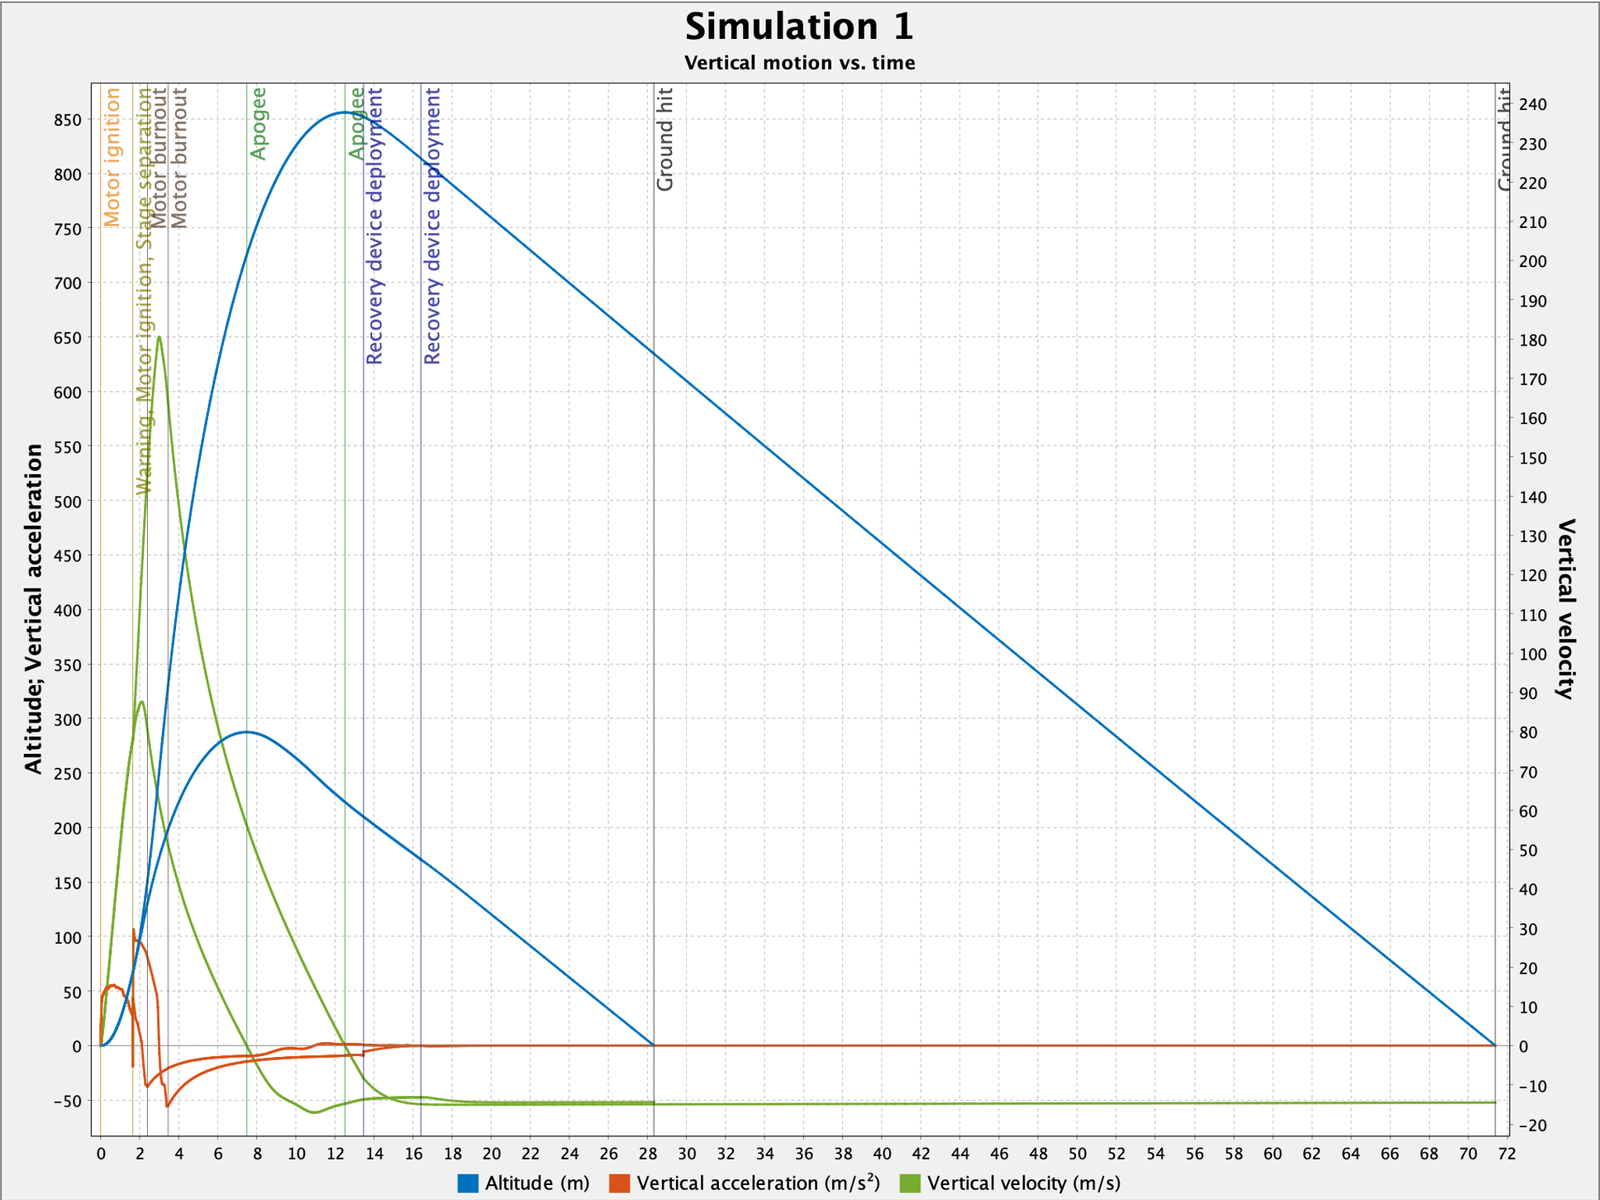
The hot-staging rocket is a two-stage vehicle, 131 cm long with the same 10.2 cm diameter. In hot staging, the upper motor lights while the two stages are still joined, and the upper motor’s exhaust pushes the stages apart. Each stage carries a fin set, because the upper stage flies alone after separation and needs fins to stay stable.
I was trying to mimic Starship’s structure: a booster below, a vented hot-staging ring, and an upper stage carrying the payload. I used a heavy nose cone to simulate that payload mass.
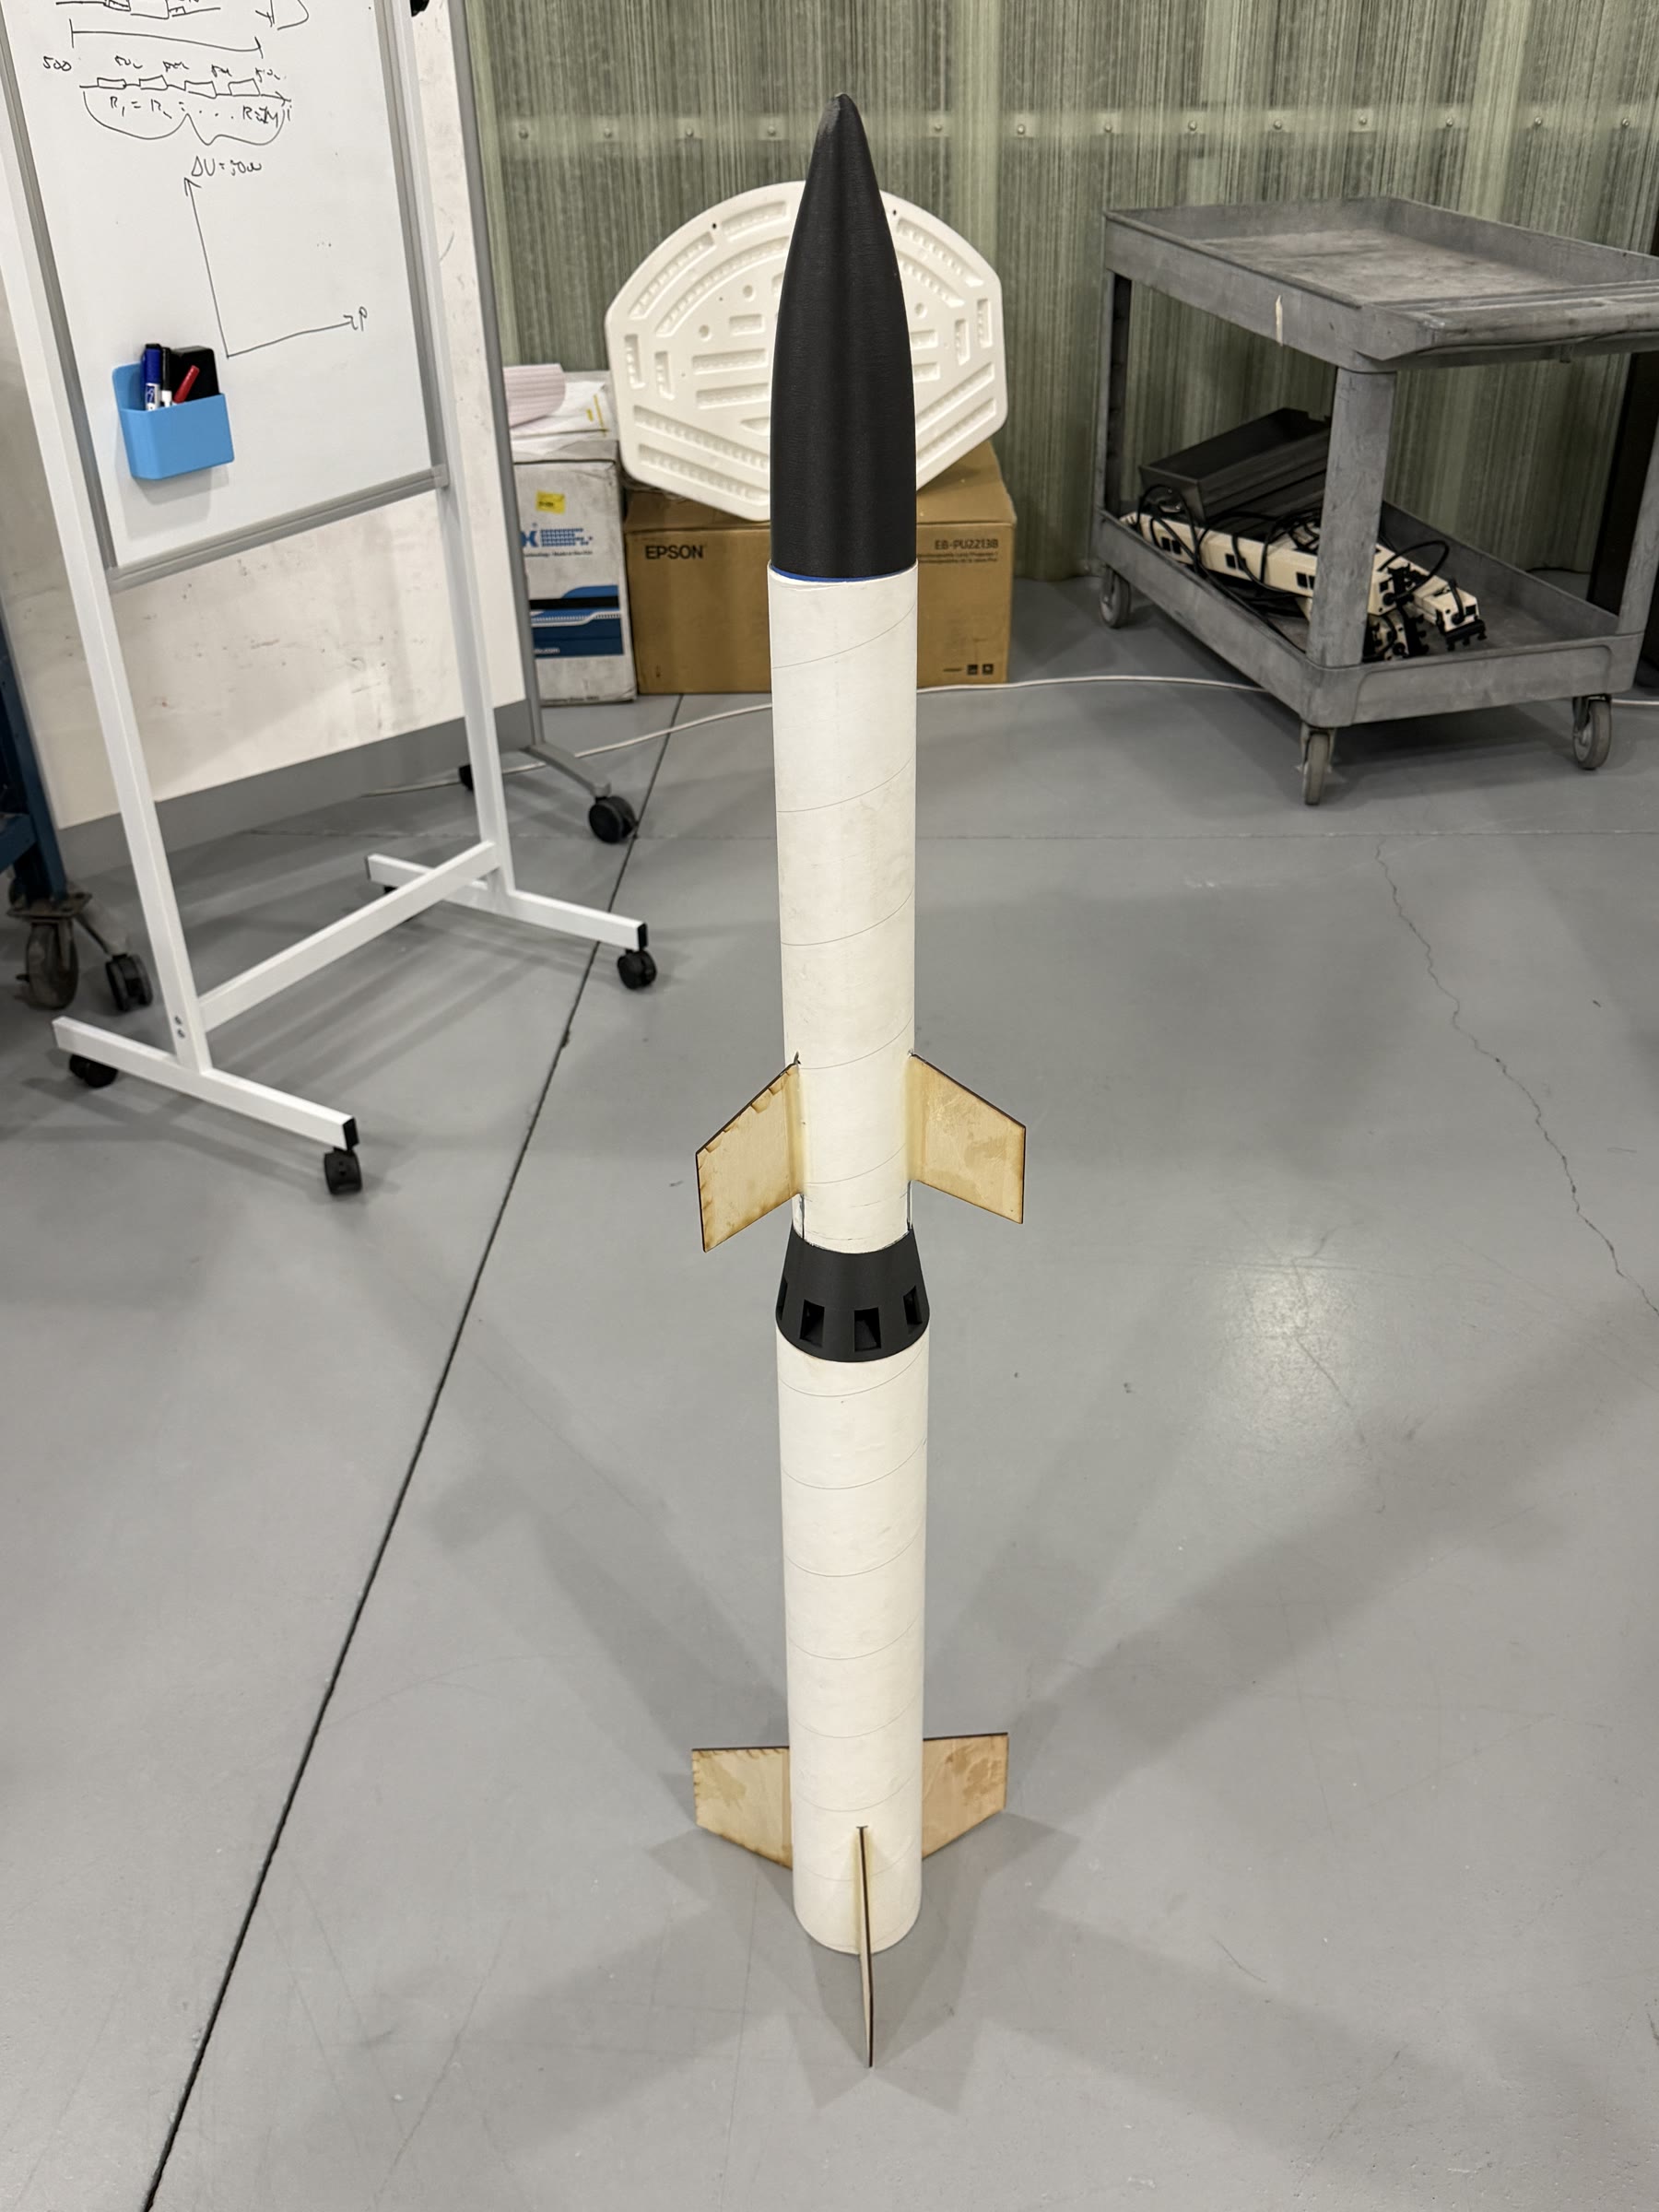
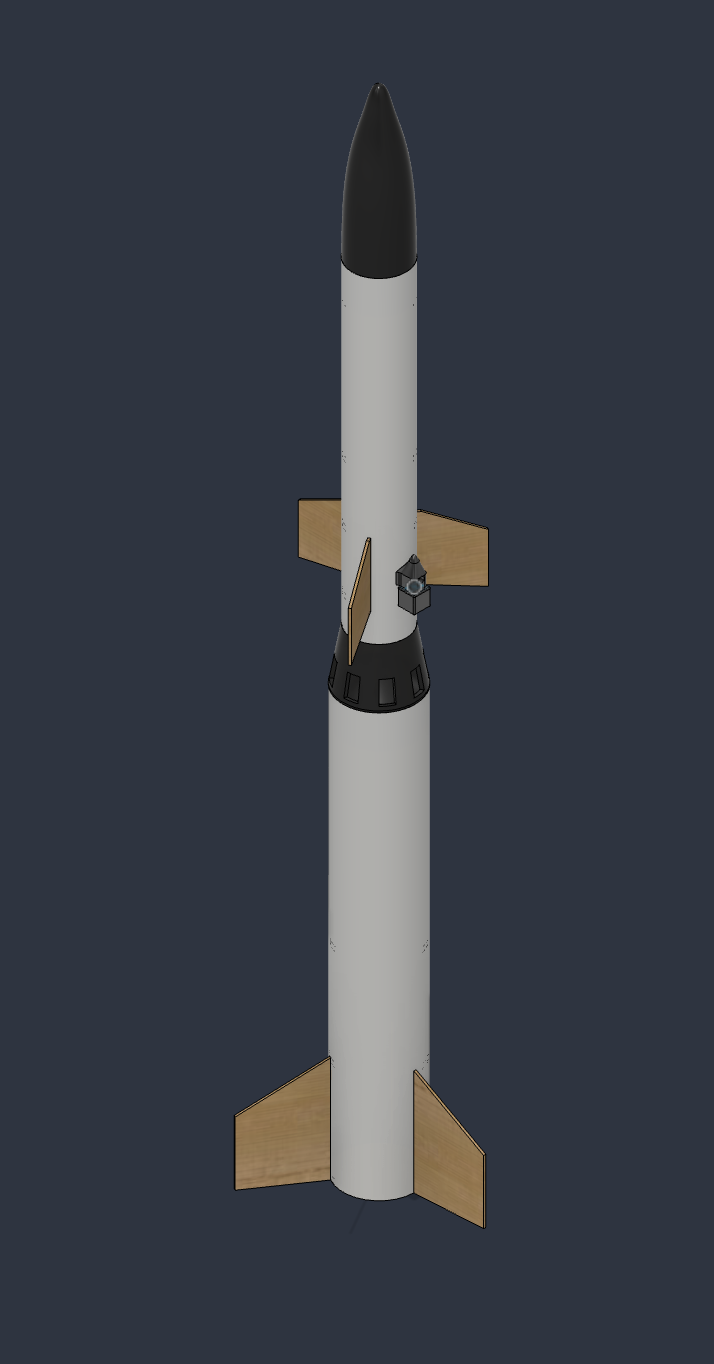
Hot-staging rings. The interstage is a black PC-CF ring with rectangular vents around the circumference. When the upper motor lights, the vents let exhaust escape from the gap between the stages instead of trapping hot gas against the top of the booster. I printed the ring in PC-CF for better thermal resistance next to the upper motor’s exhaust, and sized the vents to balance two needs: enough open area for the exhaust to escape, and enough material between the vents to hold the ring together.
FMEA. I ran a failure mode and effects analysis across avionics, pyrotechnics, staging sequence, and recovery systems to find and mitigate single-point failures before flight.
Stability Analysis
For both rockets I used OpenRocket to keep the center of gravity (CG) ahead of the center of pressure (CP). The distance between the two, divided by the body diameter, is the stability margin in calibers. With too little margin, a gust can turn the rocket sideways. With too much, the rocket weathercocks hard into the wind as the rocket leaves the rail. Both designs sit between 1 and 2 calibers at Mach 0.3: 1.39 for the Level 2 rocket and 1.53 for the hot-staging stack. The CP shifts as speed rises, and the Level 2 rocket reaches Mach 0.76, so the margin at Mach 0.3 is a first check.
Building
PC-CF nose cones. I printed the nose cones for both rockets in PC-CF, a polycarbonate filled with chopped carbon fiber. PC-CF is stiffer than PLA and holds shape at much higher temperatures, so a nose cone left in the sun at the launch field will not soften or warp.
Fiberglass layups. I glassed the fins on both rockets with a three-layer wet layup, wetting each layer of glass cloth with epoxy by hand and curing without a vacuum bag. The glass stiffens the fins against flutter and protects the fin edges on landing.
Liquid Propulsion
Chamber-wall heat-transfer analysis. Thermal modeling of combustion chamber wall temperature during the burn, informing material selection and wall thickness for the motor case.
Liquid propulsion plumbing. As part of the SSI Liquid Propulsion team, I am designing propellant feed lines, valves, and a static fire test stand for a small bipropellant engine under development.